

Why Do Agricultural Robots Need Millisecond-Level Track Response?
An autonomous navigation system can tell an agricultural robot where to go, but the planned route still needs to be accurately executed by the vehicle.
If the vehicle responds too slowly to navigation commands, it may deviate from the planned path, respond slowly when turning, or struggle to maintain stable movement.
For this reason, autonomous operation depends not only on positioning and navigation accuracy, but also on the responsiveness of the vehicle's drive system.
In-Wheel Motors: Direct and Independent Drive
Unlike conventional mechanical transmission systems, in-wheel motors deliver power directly to the drive wheels of the tracks.
This reduces the number of mechanical transmission components and allows control commands to be transferred more directly to the driving system.
More importantly, the left and right tracks can be controlled independently. This provides the foundation for differential steering, precise turning, and tight-radius maneuvering.
Millisecond-Level Response: Every Command Matters
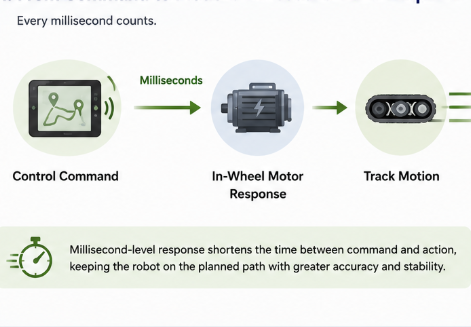
Agricultural robots continuously receive commands while operating. Changes in direction, speed, and turning all require the drive system to respond quickly.
Millisecond-level response shortens the time between a control command and the corresponding movement of the tracks.
This allows the robot to adjust its motion more quickly and keep its actual trajectory closer to the planned path.
This responsiveness becomes especially important during turning, maneuvering, and operations on uneven terrain.
Independent Track Control: More Precise Movement
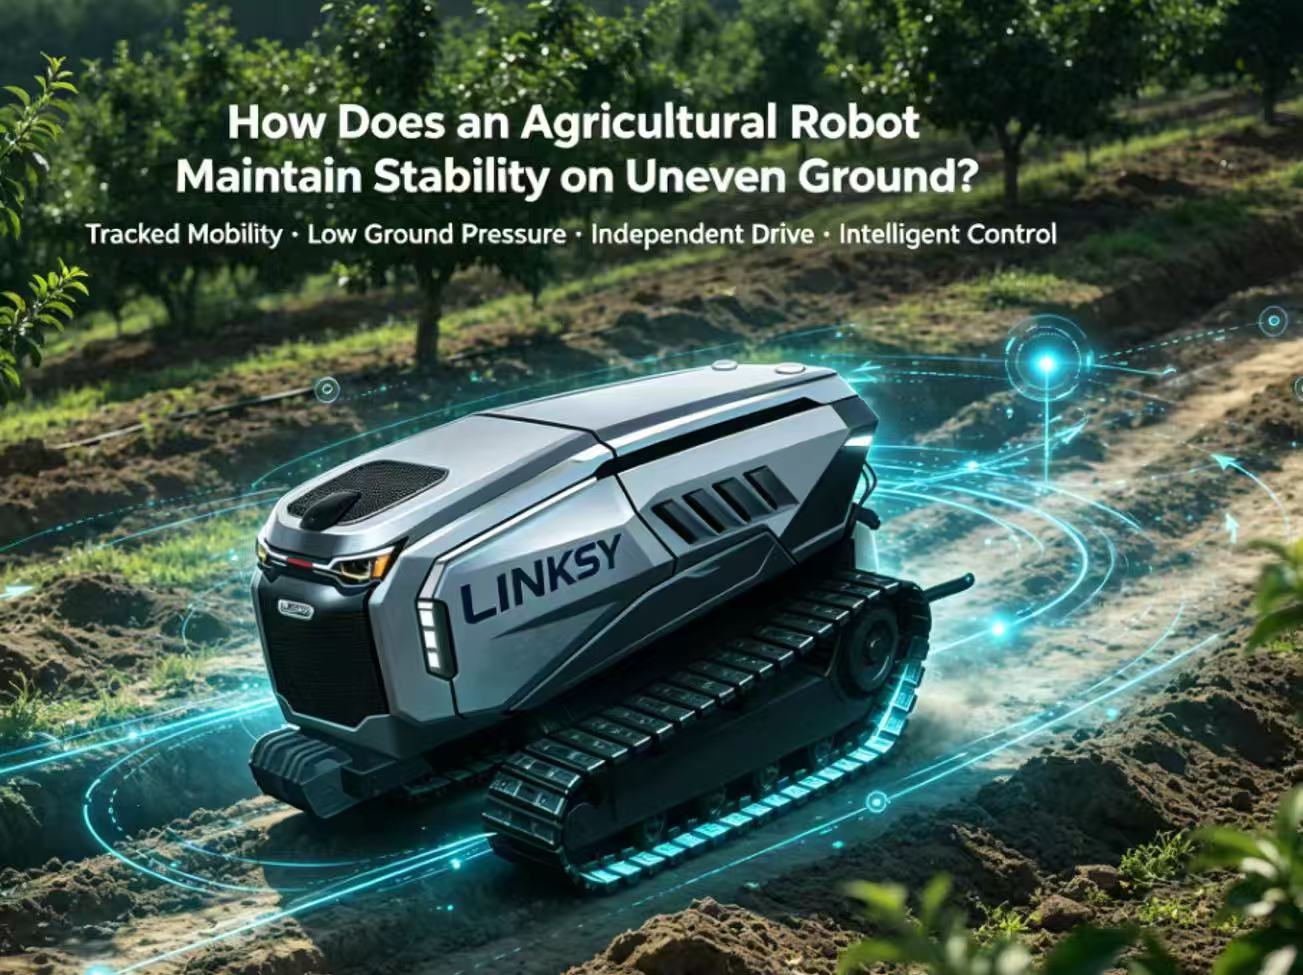
Agricultural robots do not always operate on flat and open ground.
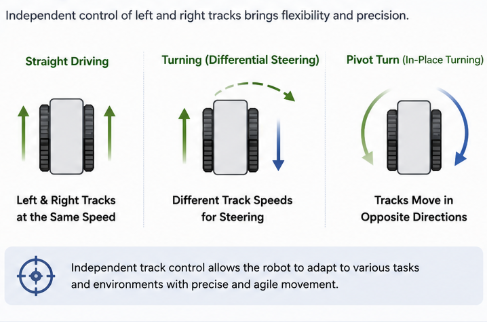
Orchard rows, slopes, and narrow working areas can require frequent changes in direction. With independent track control, the robot can adjust the operating speed of each side according to the required movement.
For example:
Straight driving: The left and right tracks operate in coordination.
Turning: Different track speeds create differential steering.
Turning in place: The tracks can move in opposite directions, allowing the robot to turn within a very small area.
This flexibility gives tracked agricultural robots greater maneuverability in confined and challenging environments.
Complex Terrain Requires Faster Control
Agricultural environments are often more challenging than conventional roads.
Slopes, uneven ground, and narrow orchard rows all place higher demands on vehicle control.
In these environments, the machine needs not only good terrain capability, but also the ability to adjust its movement quickly according to changing conditions.
Fast response + independent track control + tracked mobility
help agricultural robots respond more effectively to steering and speed changes, improving stability and maneuverability in complex environments.
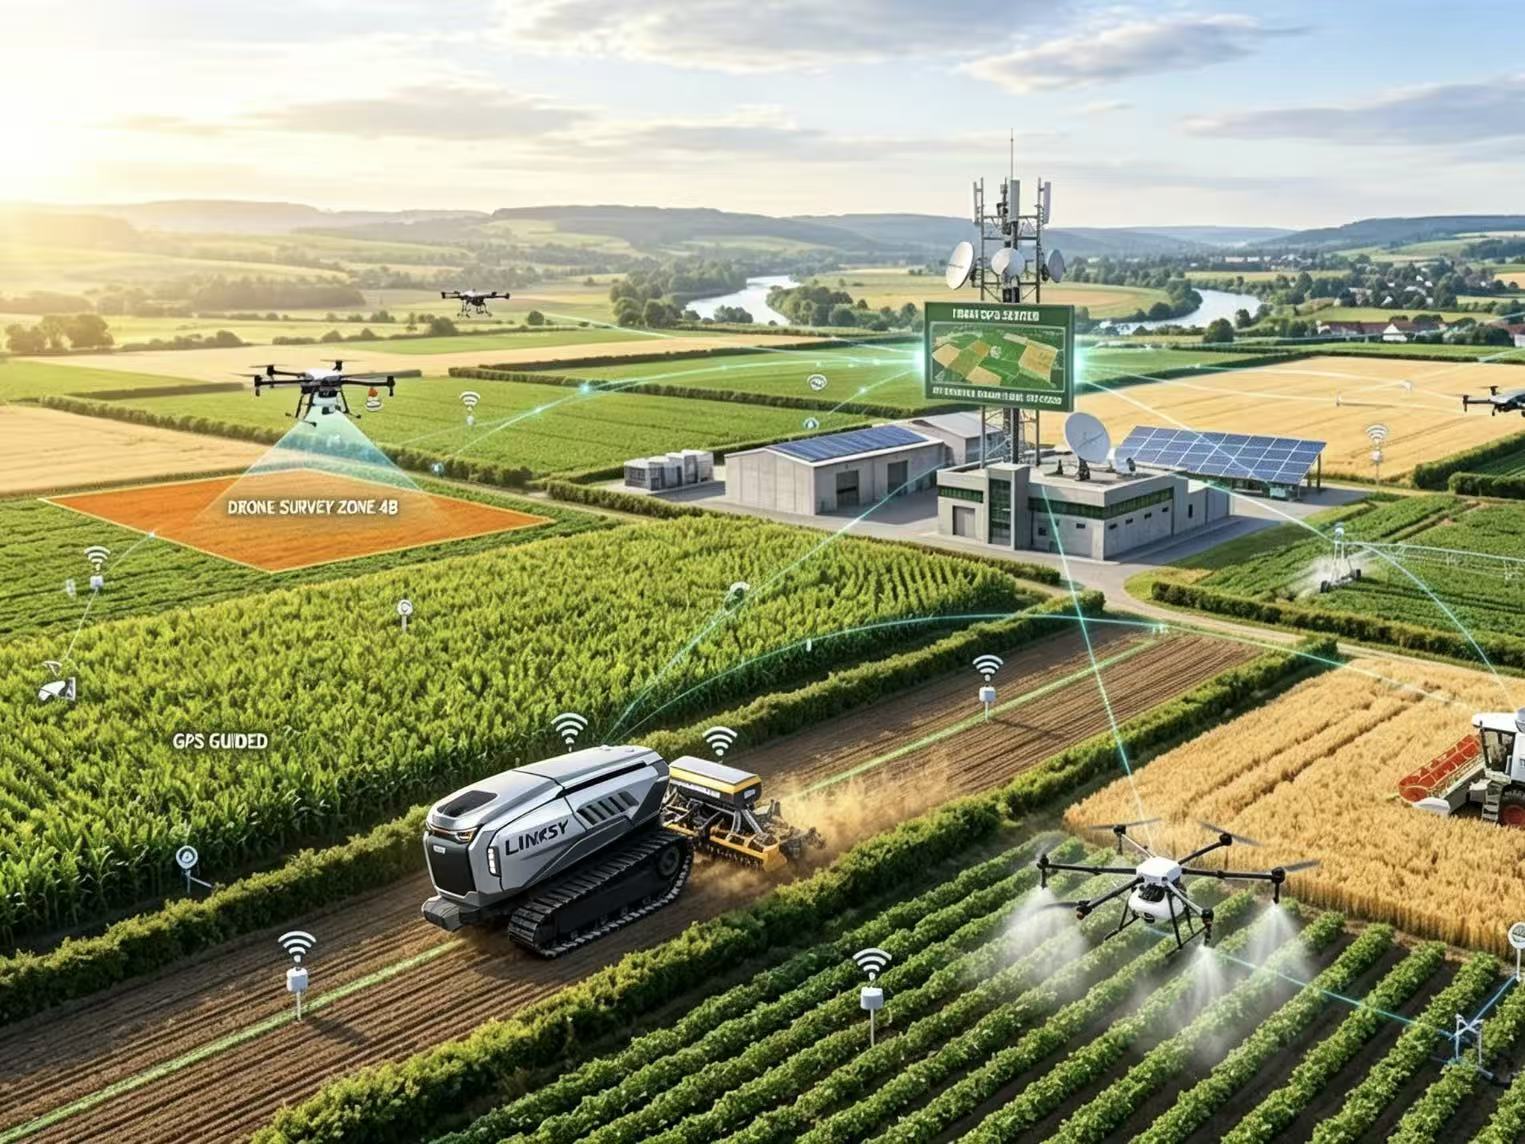
RTK Locates. Navigation Plans. Motors Execute.
Autonomous driving is not achieved by a single technology.
It can be understood as a complete chain:
When precise positioning, path planning, vehicle control, and responsive drive systems work together, an agricultural robot can move from simply knowing its location to truly operating autonomously.
LINKSY®65 HP: Precision Navigation Meets Responsive Mobility
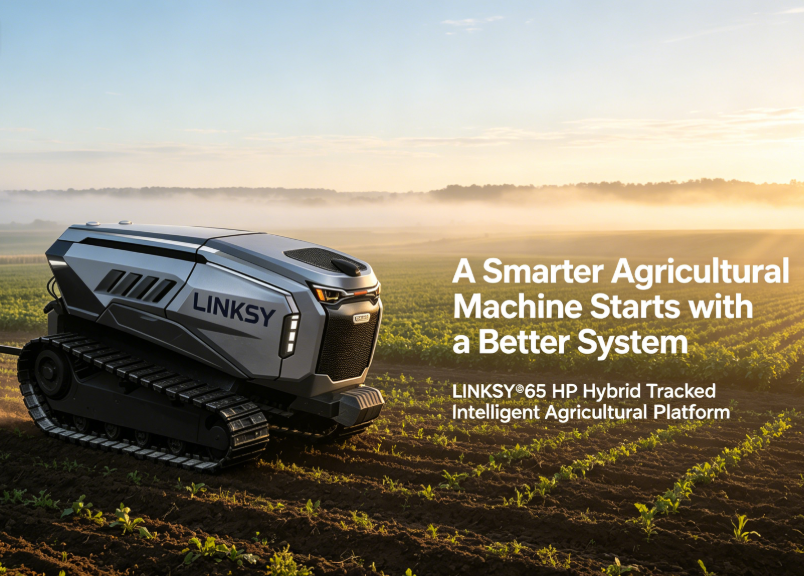
SENYTA's LINKSY®65 HP Hybrid Tracked Intelligent Agricultural Platform combines intelligent navigation with a tracked mobility system designed for complex agricultural environments.
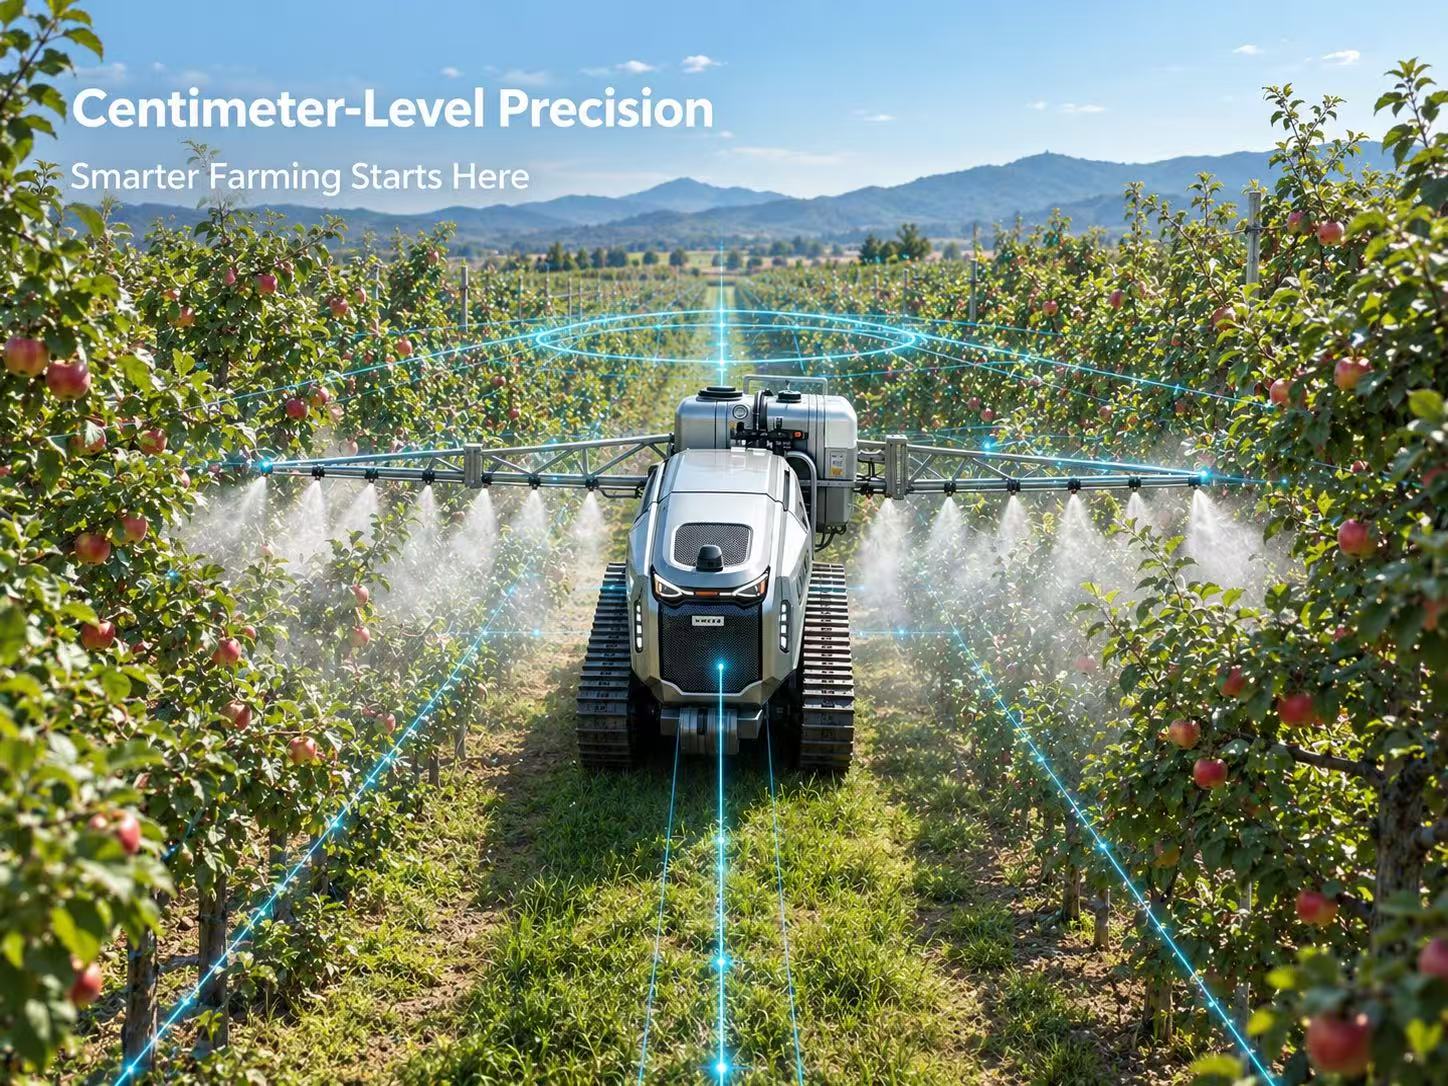
With RTK positioning, the Autonomous Navigation System, intelligent vehicle control, and in-wheel motor drive, the platform can translate navigation commands into precise vehicle movements.
The navigation system plans the route, while the drive system executes the movement.
This combination allows LINKSY®65 HP to go beyond simply driving autonomously and achieve more responsive and precise motion control during agricultural operations.