
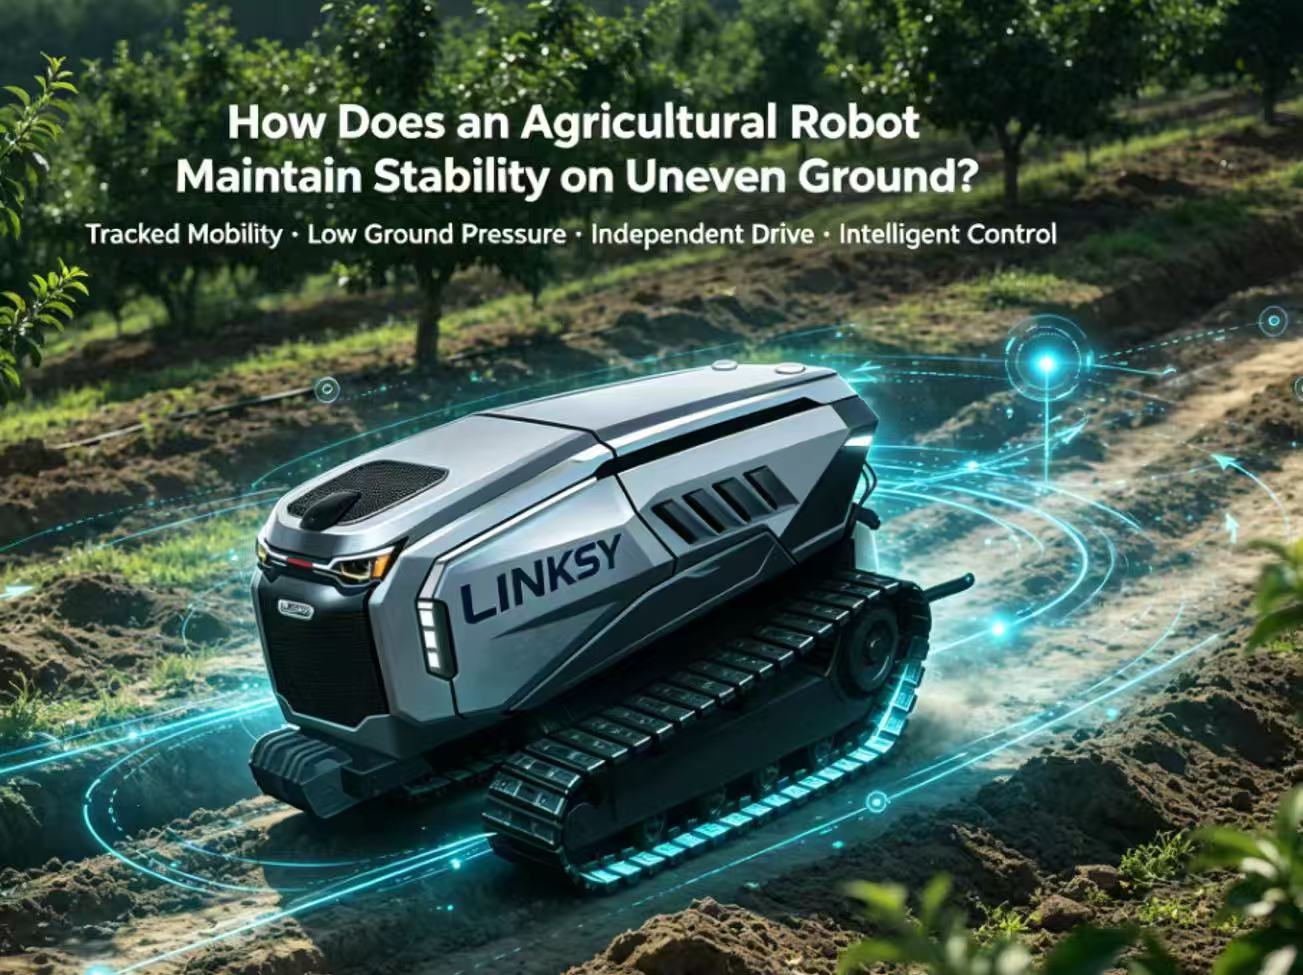
How Does an Agricultural Robot Maintain Stability on Uneven Ground?
Why Is Stability So Important in Agricultural Robotics?
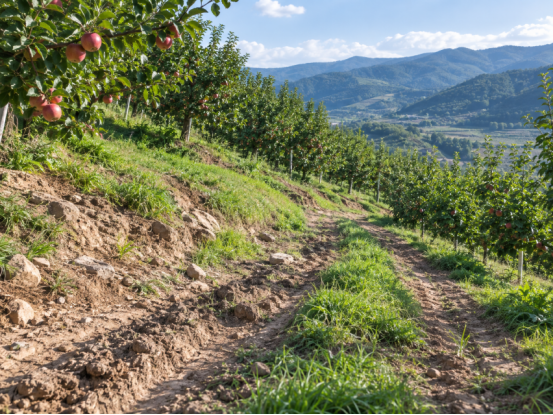
Agricultural environments are rarely perfectly flat.
Unlike roads and paved surfaces, farmland may include slopes, uneven ground, soft soil, ruts, and changing surface conditions. For agricultural robots, these environments can affect traction, vehicle stability, and movement accuracy.
Stability is particularly important for autonomous equipment.
When a robot is following a planned route, even small changes in its movement can affect navigation accuracy and operation quality. During spraying, transportation, mowing, or other field operations, maintaining stable movement helps the machine follow its intended path and perform tasks more consistently.
For this reason, agricultural robot stability is not determined by one component alone. It depends on the interaction between the mobility system, ground contact, drive system, and intelligent control.
Tracked Mobility: A Larger Contact Area
One of the key factors affecting stability is how the machine interacts with the ground.
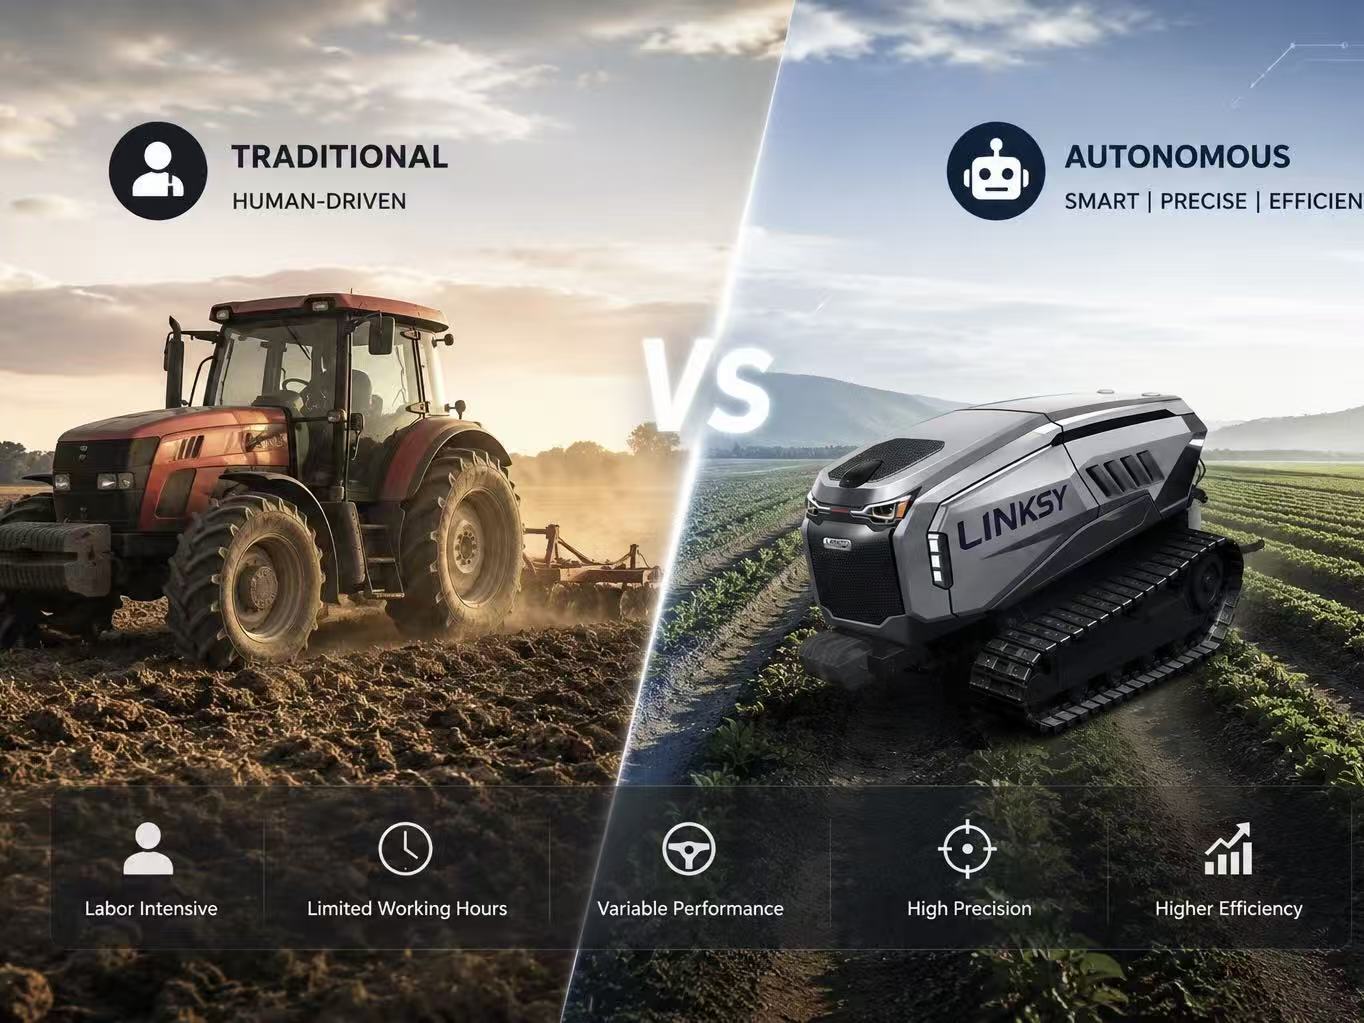
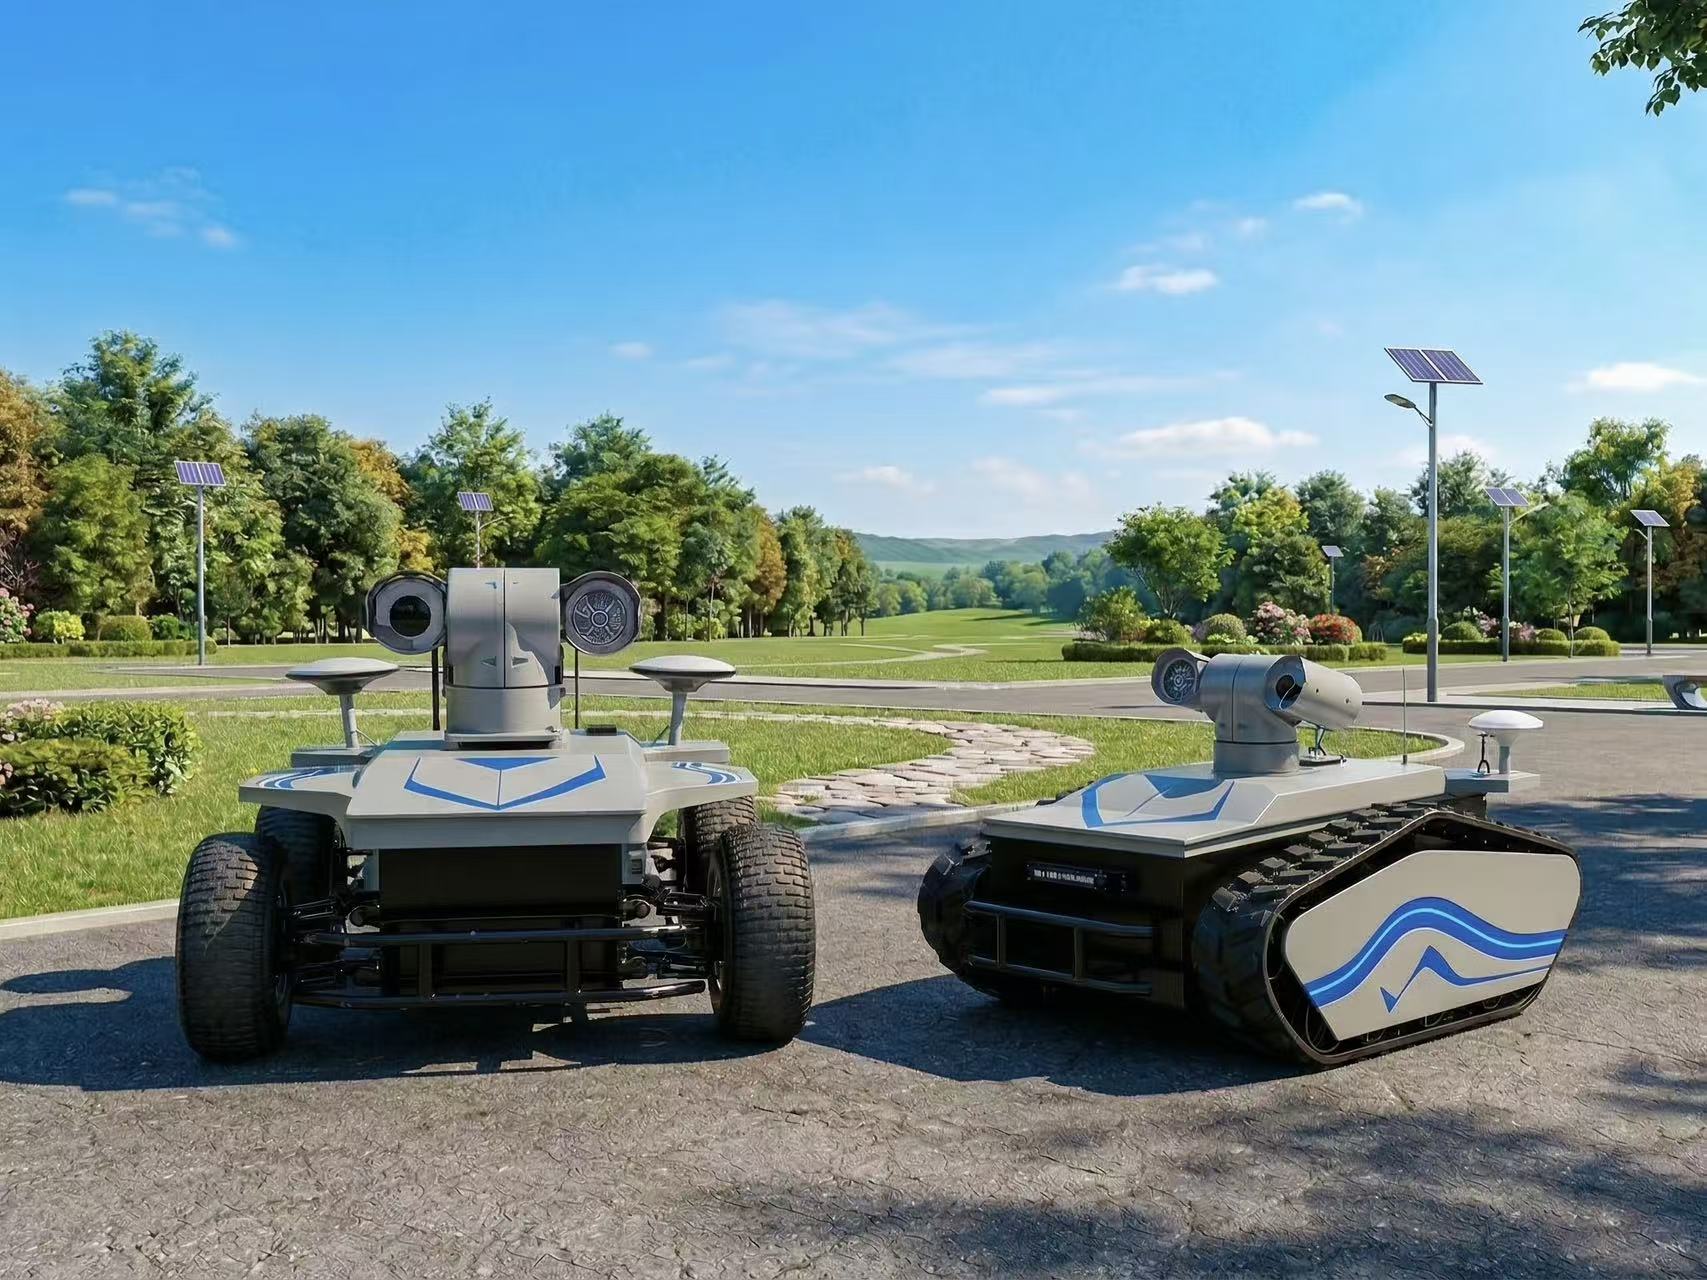
Wheeled vehicles concentrate their weight through relatively small contact areas. Under soft or uneven conditions, this can increase ground pressure and make the vehicle more likely to sink or lose traction.
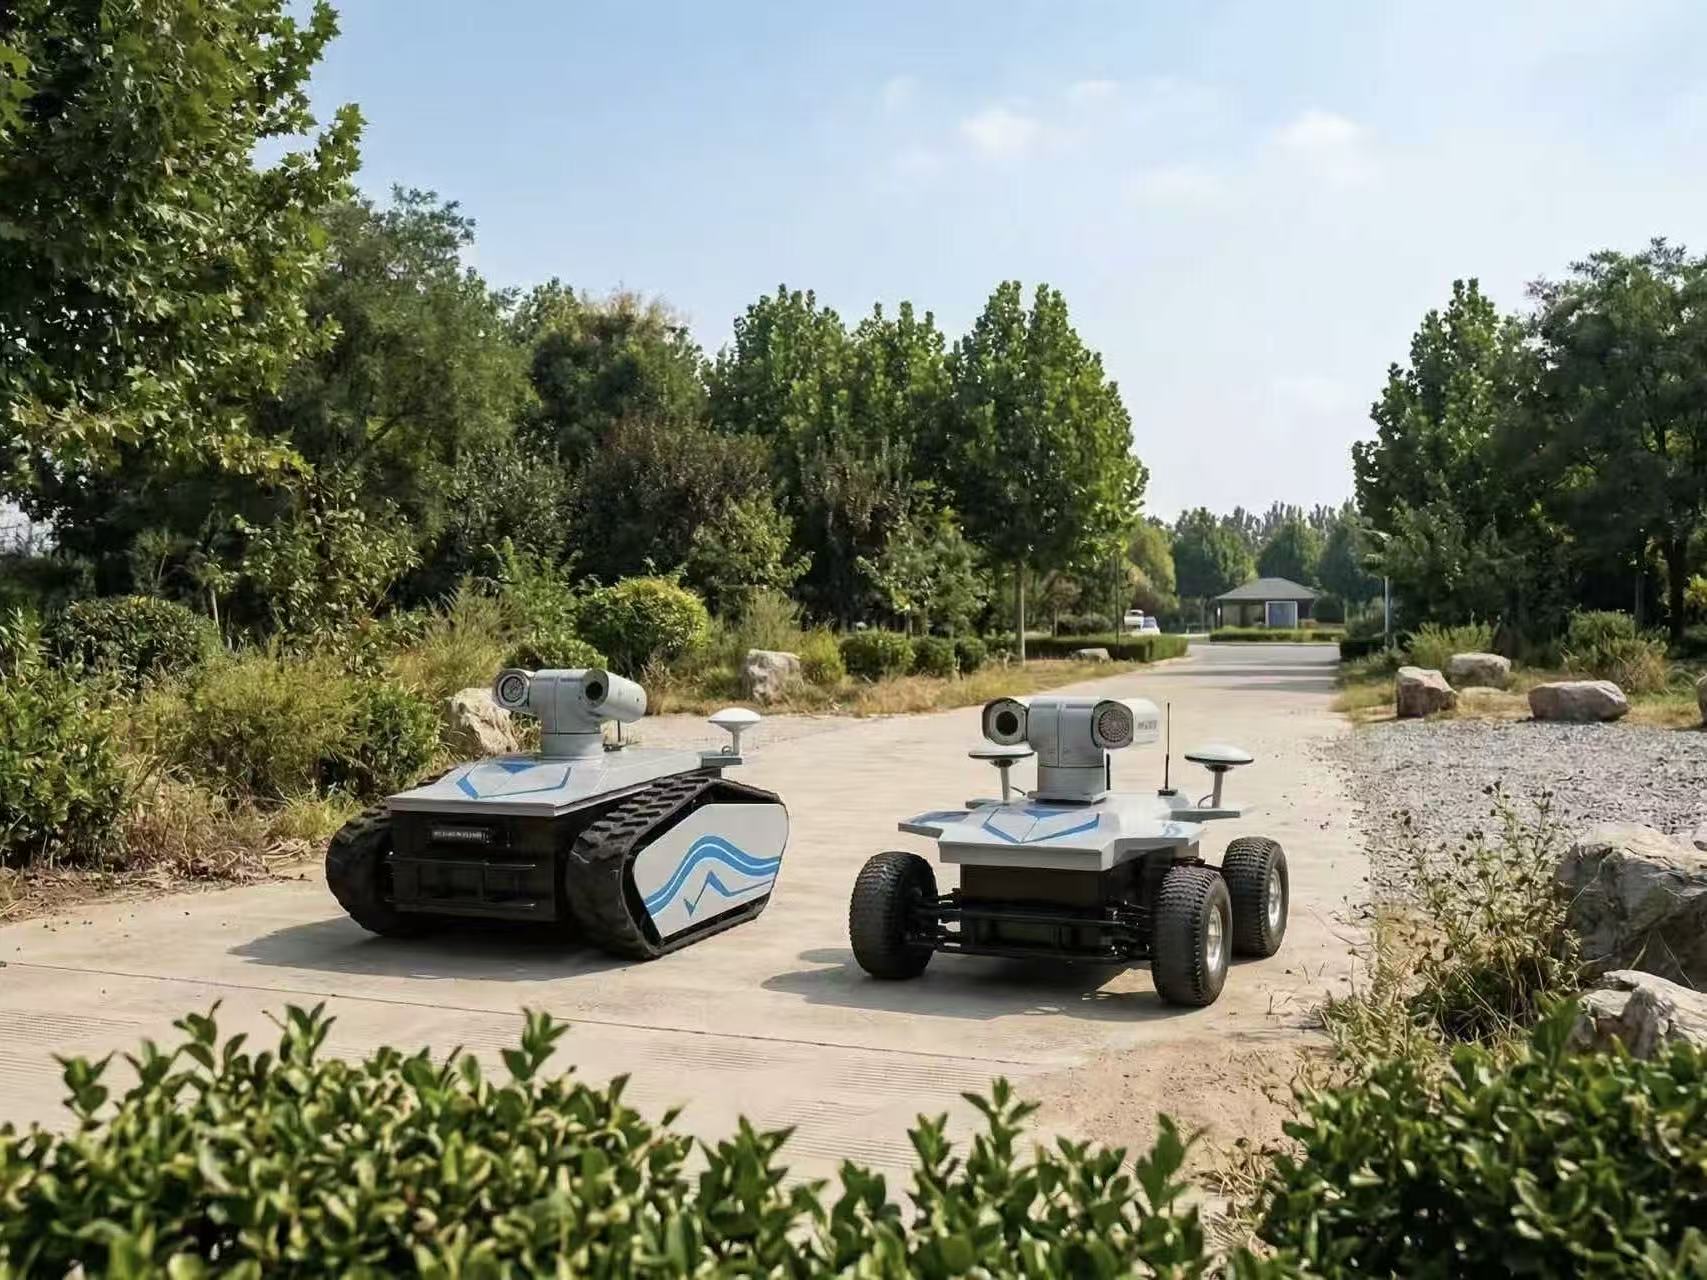
Tracked systems distribute the machine's weight over a larger contact area.
This can reduce ground pressure and improve contact with the surface, making tracked platforms particularly suitable for agricultural environments where soil conditions can vary significantly.
For agricultural robots, a larger contact area also provides a more stable foundation for movement, especially when operating on soft soil or uneven ground.
Low Ground Pressure Helps Protect the Soil
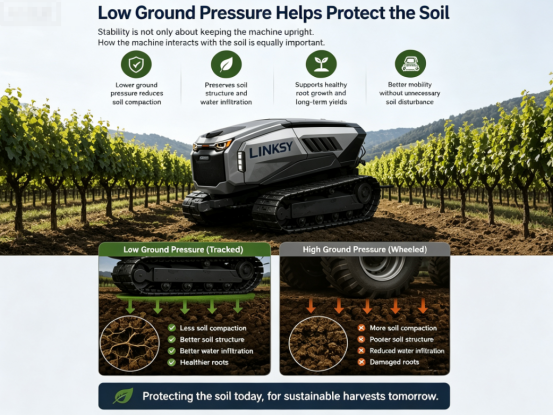
Stability is not only about keeping the machine upright. How the machine interacts with the soil is equally important.
High ground pressure can increase soil compaction, particularly when heavy equipment repeatedly travels along the same working area.
Tracked platforms can distribute their weight across a larger contact area, helping reduce ground pressure.
This is particularly valuable in agricultural applications where maintaining soil structure is an important consideration.
For intelligent farming equipment, better mobility should not come at the cost of unnecessary soil disturbance.
Independent Drive: Adapting Movement to the Terrain
A stable platform also needs precise control over how it moves.
With independent drive systems, the left and right tracks can be controlled separately. This allows the robot to adjust speed and direction according to different operating conditions.
During turning, for example, the two tracks can operate at different speeds to achieve differential steering. This gives the robot greater maneuverability in narrow orchard rows and other confined spaces.
On uneven terrain, independent drive also allows the movement system to respond more precisely to changes in the robot's operating state.
In other words, stability is not simply about having a strong chassis. It also depends on how precisely the machine can control its movement.
Intelligent Control Turns Mobility into Stability
Mechanical design provides the foundation, but intelligent control determines how effectively the machine responds to its environment.
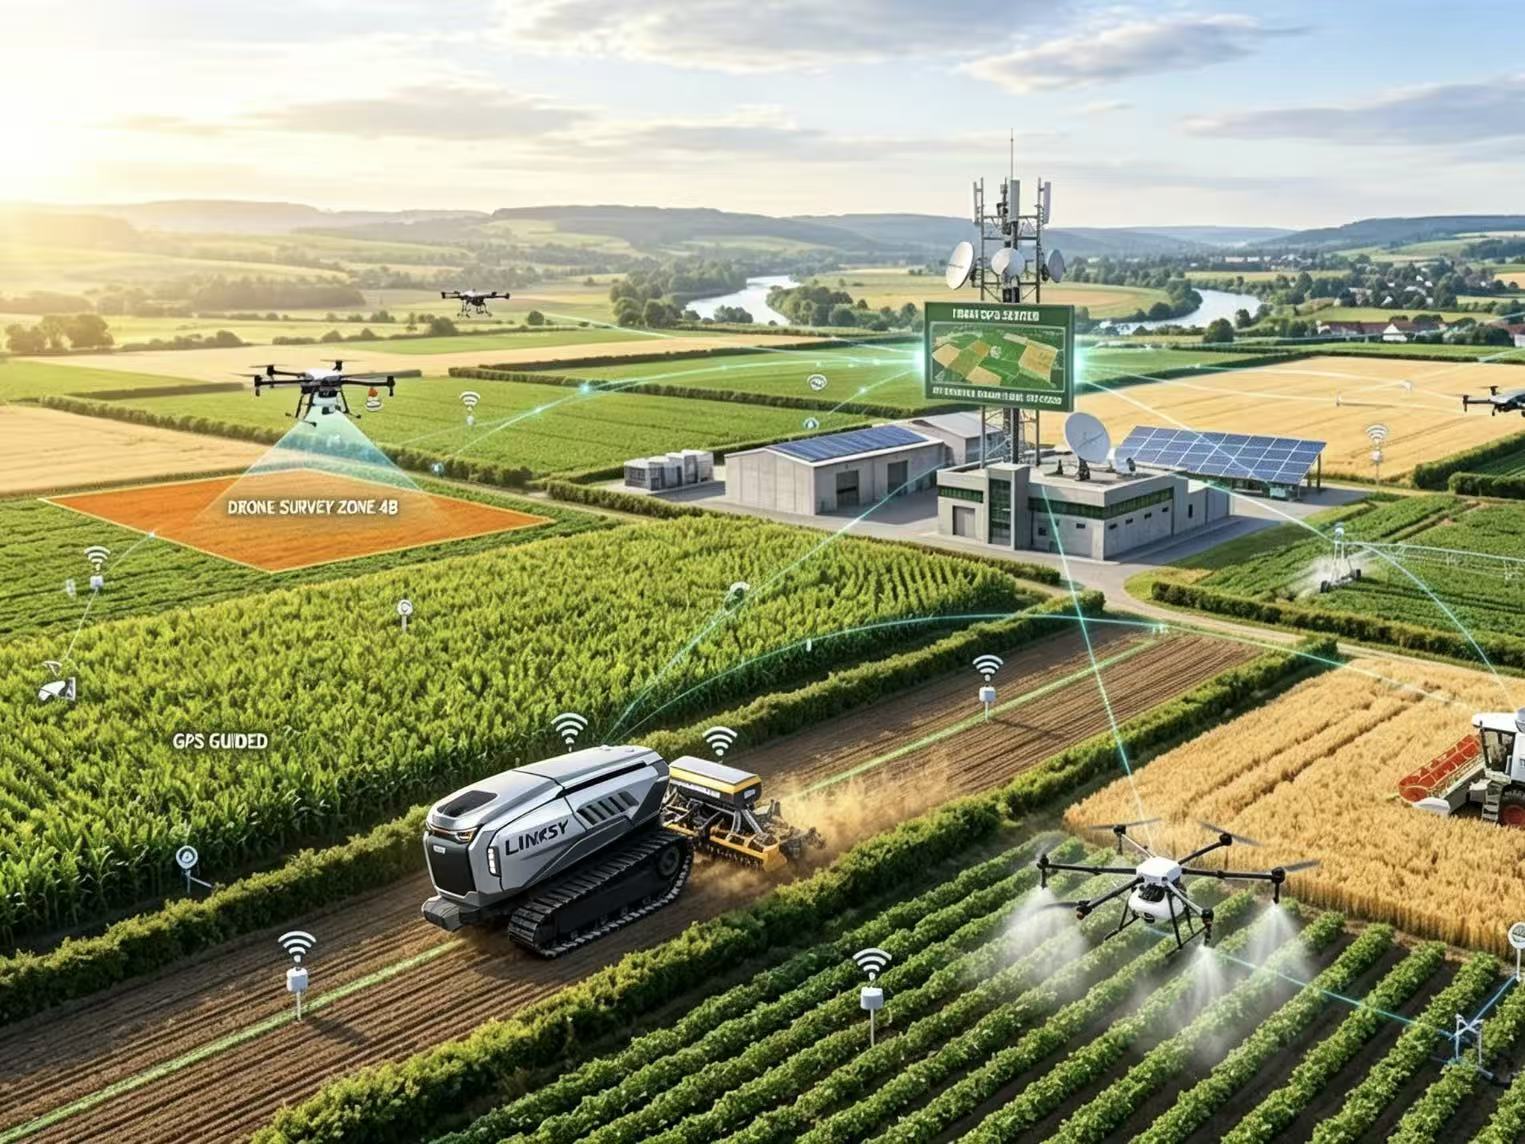
An autonomous agricultural robot continuously receives information from its navigation and sensing systems. The control system then processes this information and sends movement commands to the drive system.
This creates a continuous cycle:
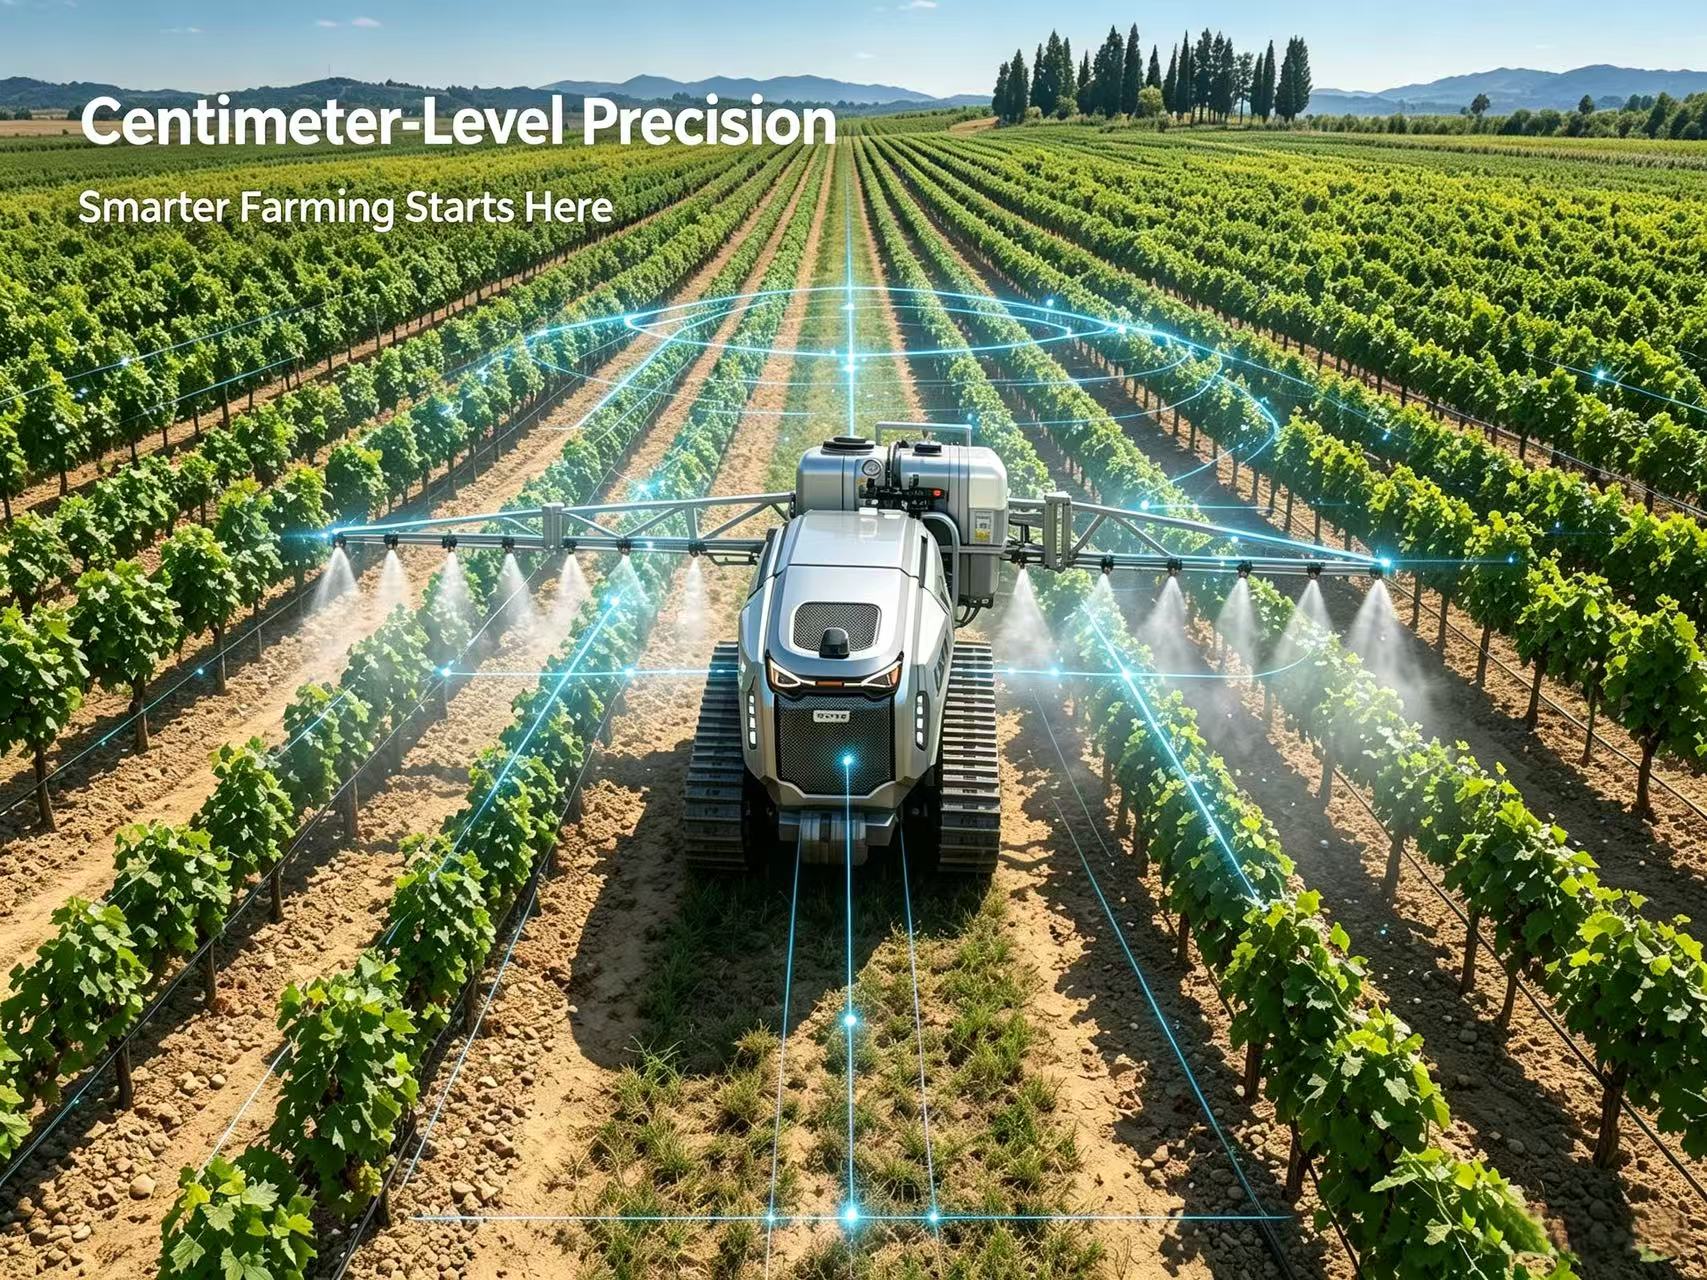
RTK provides accurate positioning.
The navigation system determines the planned route.
The control system calculates the required movement.
The drive system executes the command.
Feedback then helps the system continue adjusting its movement.
This interaction allows the robot to maintain more consistent motion while operating in changing agricultural environments.
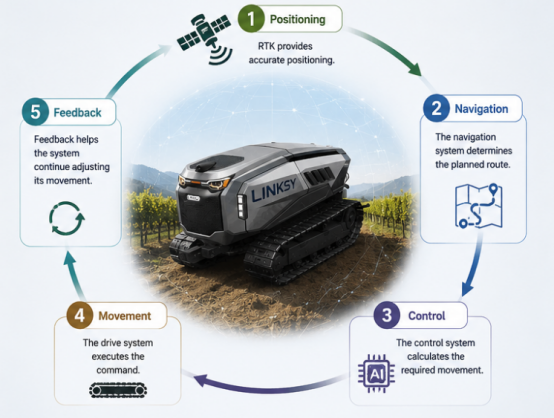
LINKSY®65 HP: Built for Complex Agricultural Environments
SENYTA's LINKSY®65 HP Hybrid Tracked Intelligent Agricultural Platform combines tracked mobility, hybrid power, independent drive, and intelligent navigation technologies.
Its tracked design provides a larger ground contact area, while the independent drive system enables precise control of the two tracks.
Combined with RTK-based autonomous navigation and intelligent vehicle control, the platform is designed to provide stable and accurate movement across orchards, slopes, and other challenging agricultural environments.
This integrated approach allows LINKSY®65 HP to go beyond simply moving through difficult terrain. It provides a foundation for autonomous agricultural operations where stability, precision, and adaptability are equally important.
Stability Is a System, Not a Single Feature
For agricultural robots, stability comes from the interaction of multiple technologies.
- Tracked mobility provides a stable contact foundation.
- Low ground pressure helps reduce the impact on the soil.
- Independent drive enables precise movement control.
- RTK navigation provides accurate positioning.
- Intelligent control connects these technologies and turns them into coordinated movement.
As agricultural robotics continues to evolve, machines will need to operate in increasingly diverse environments.
The goal is not simply to build robots that can move autonomously, but robots that can move accurately, reliably, and confidently in the real world.